Angelo Moroncelli
Angelo Moroncelli
Ph.D. Researcher — Generative AI for Robotics
IDSIA USI–SUPSI · Lugano, Switzerland
I work at the intersection of generative modeling, reinforcement learning, and robotics. My research investigates how generative optimization can enable robotic agents to move beyond the imitation of skills learned from labeled demonstrations. I initially explored the out-of-distribution behavior of generative policies, investigating how they behave beyond their training distribution. More recently, I have been studying how generative priors, such as diffusion and flow-based policies and vision-language-action models, can be integrated with reinforcement learning to guide exploration and optimize behavior beyond the training data.
Selected Research
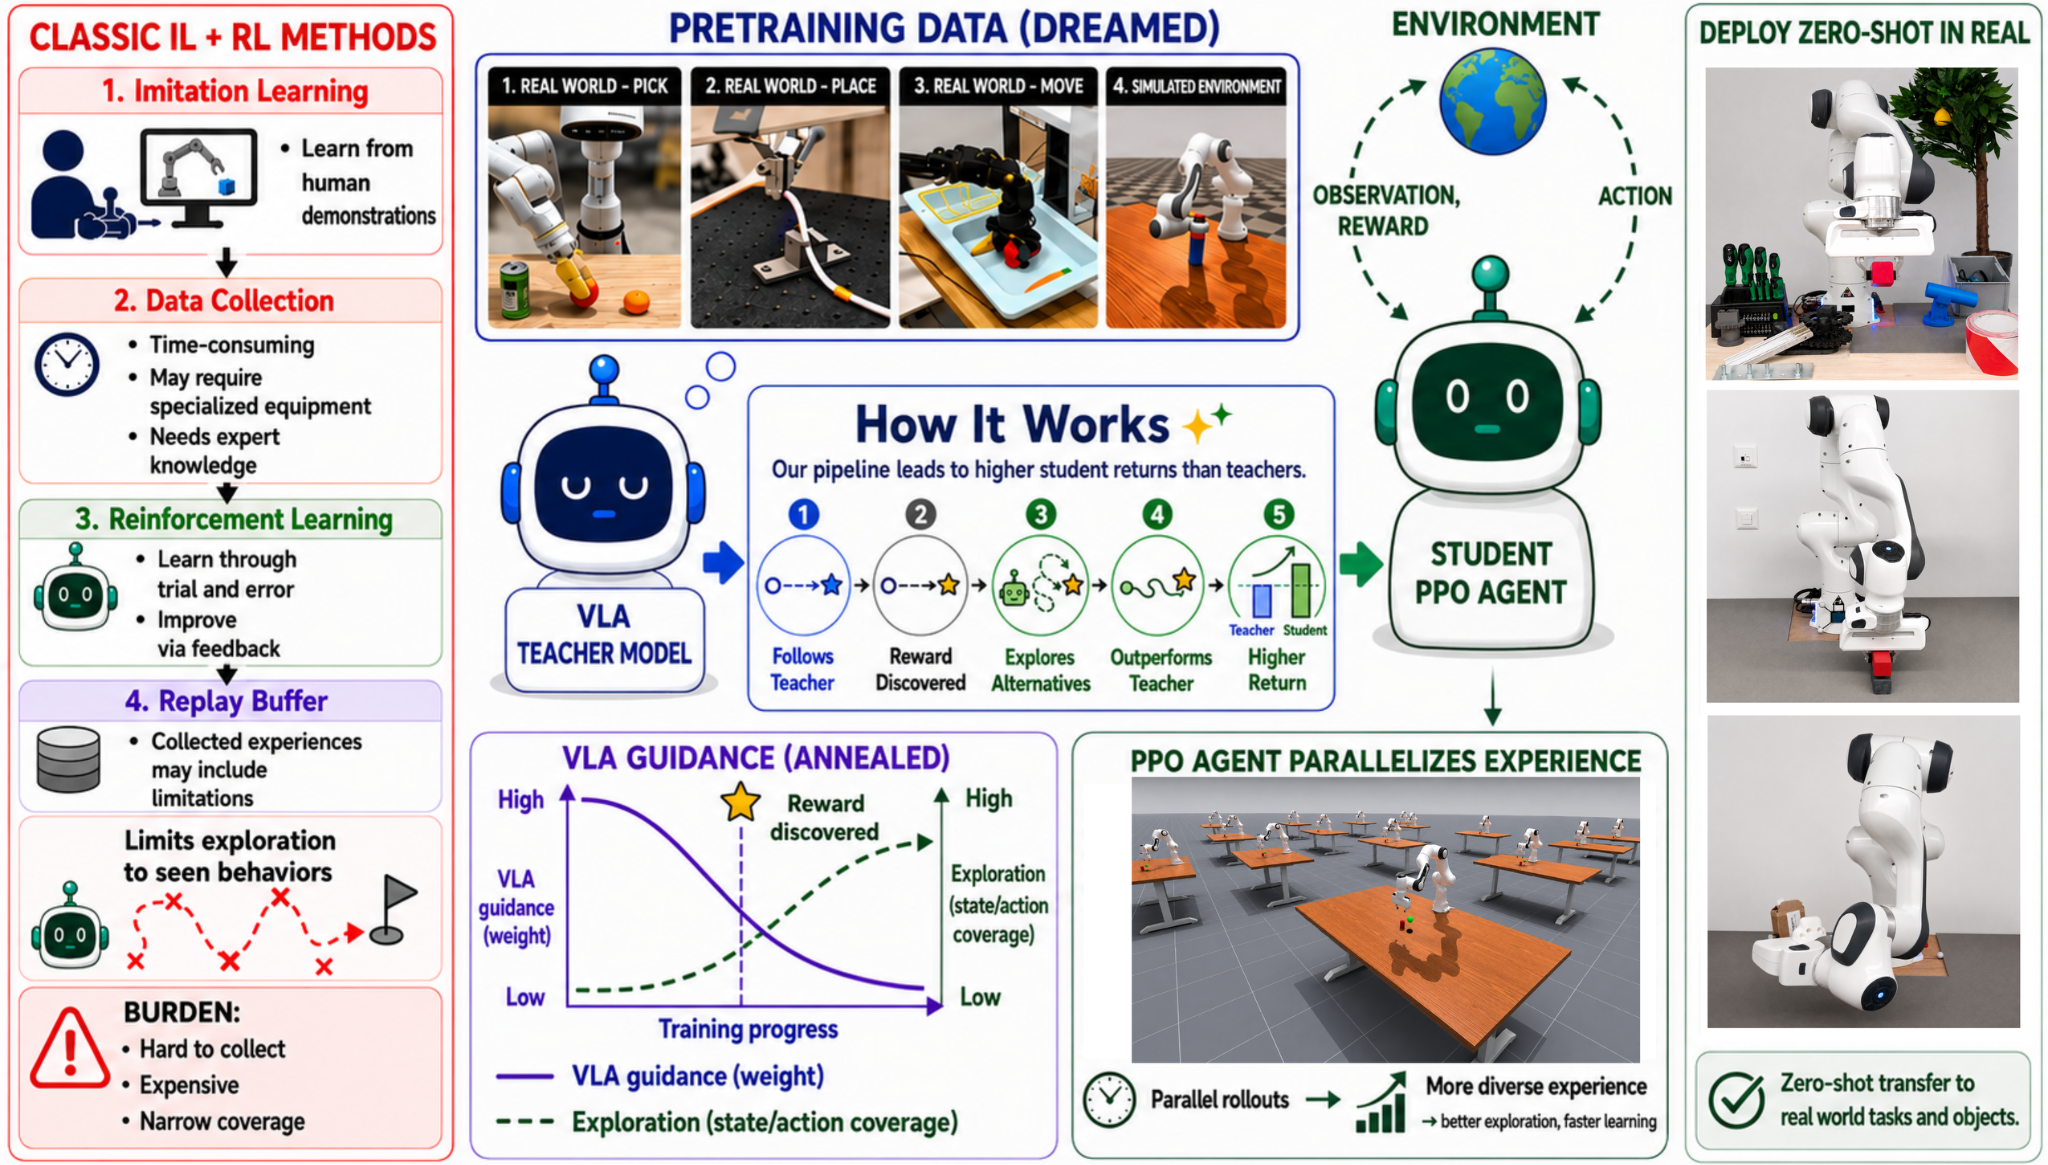
Vision-Language-Action Jump-Starting for Reinforcement Learning Robotic Agents
IEEE ICRA 2026 Workshop on RL4IL
Using VLA priors to jump-start reinforcement-learning agents for robotic control.
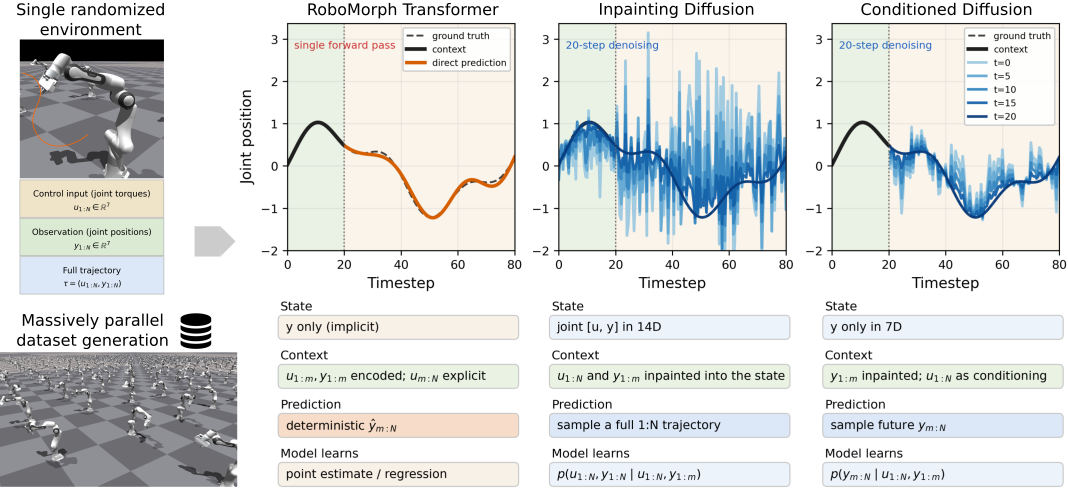
Diffusion Sequence Models for Generative In-Context Meta-Learning of Robot Dynamics
IEEE CDC 2026
Generative sequence modeling for in-context adaptation and learning of robot dynamics.
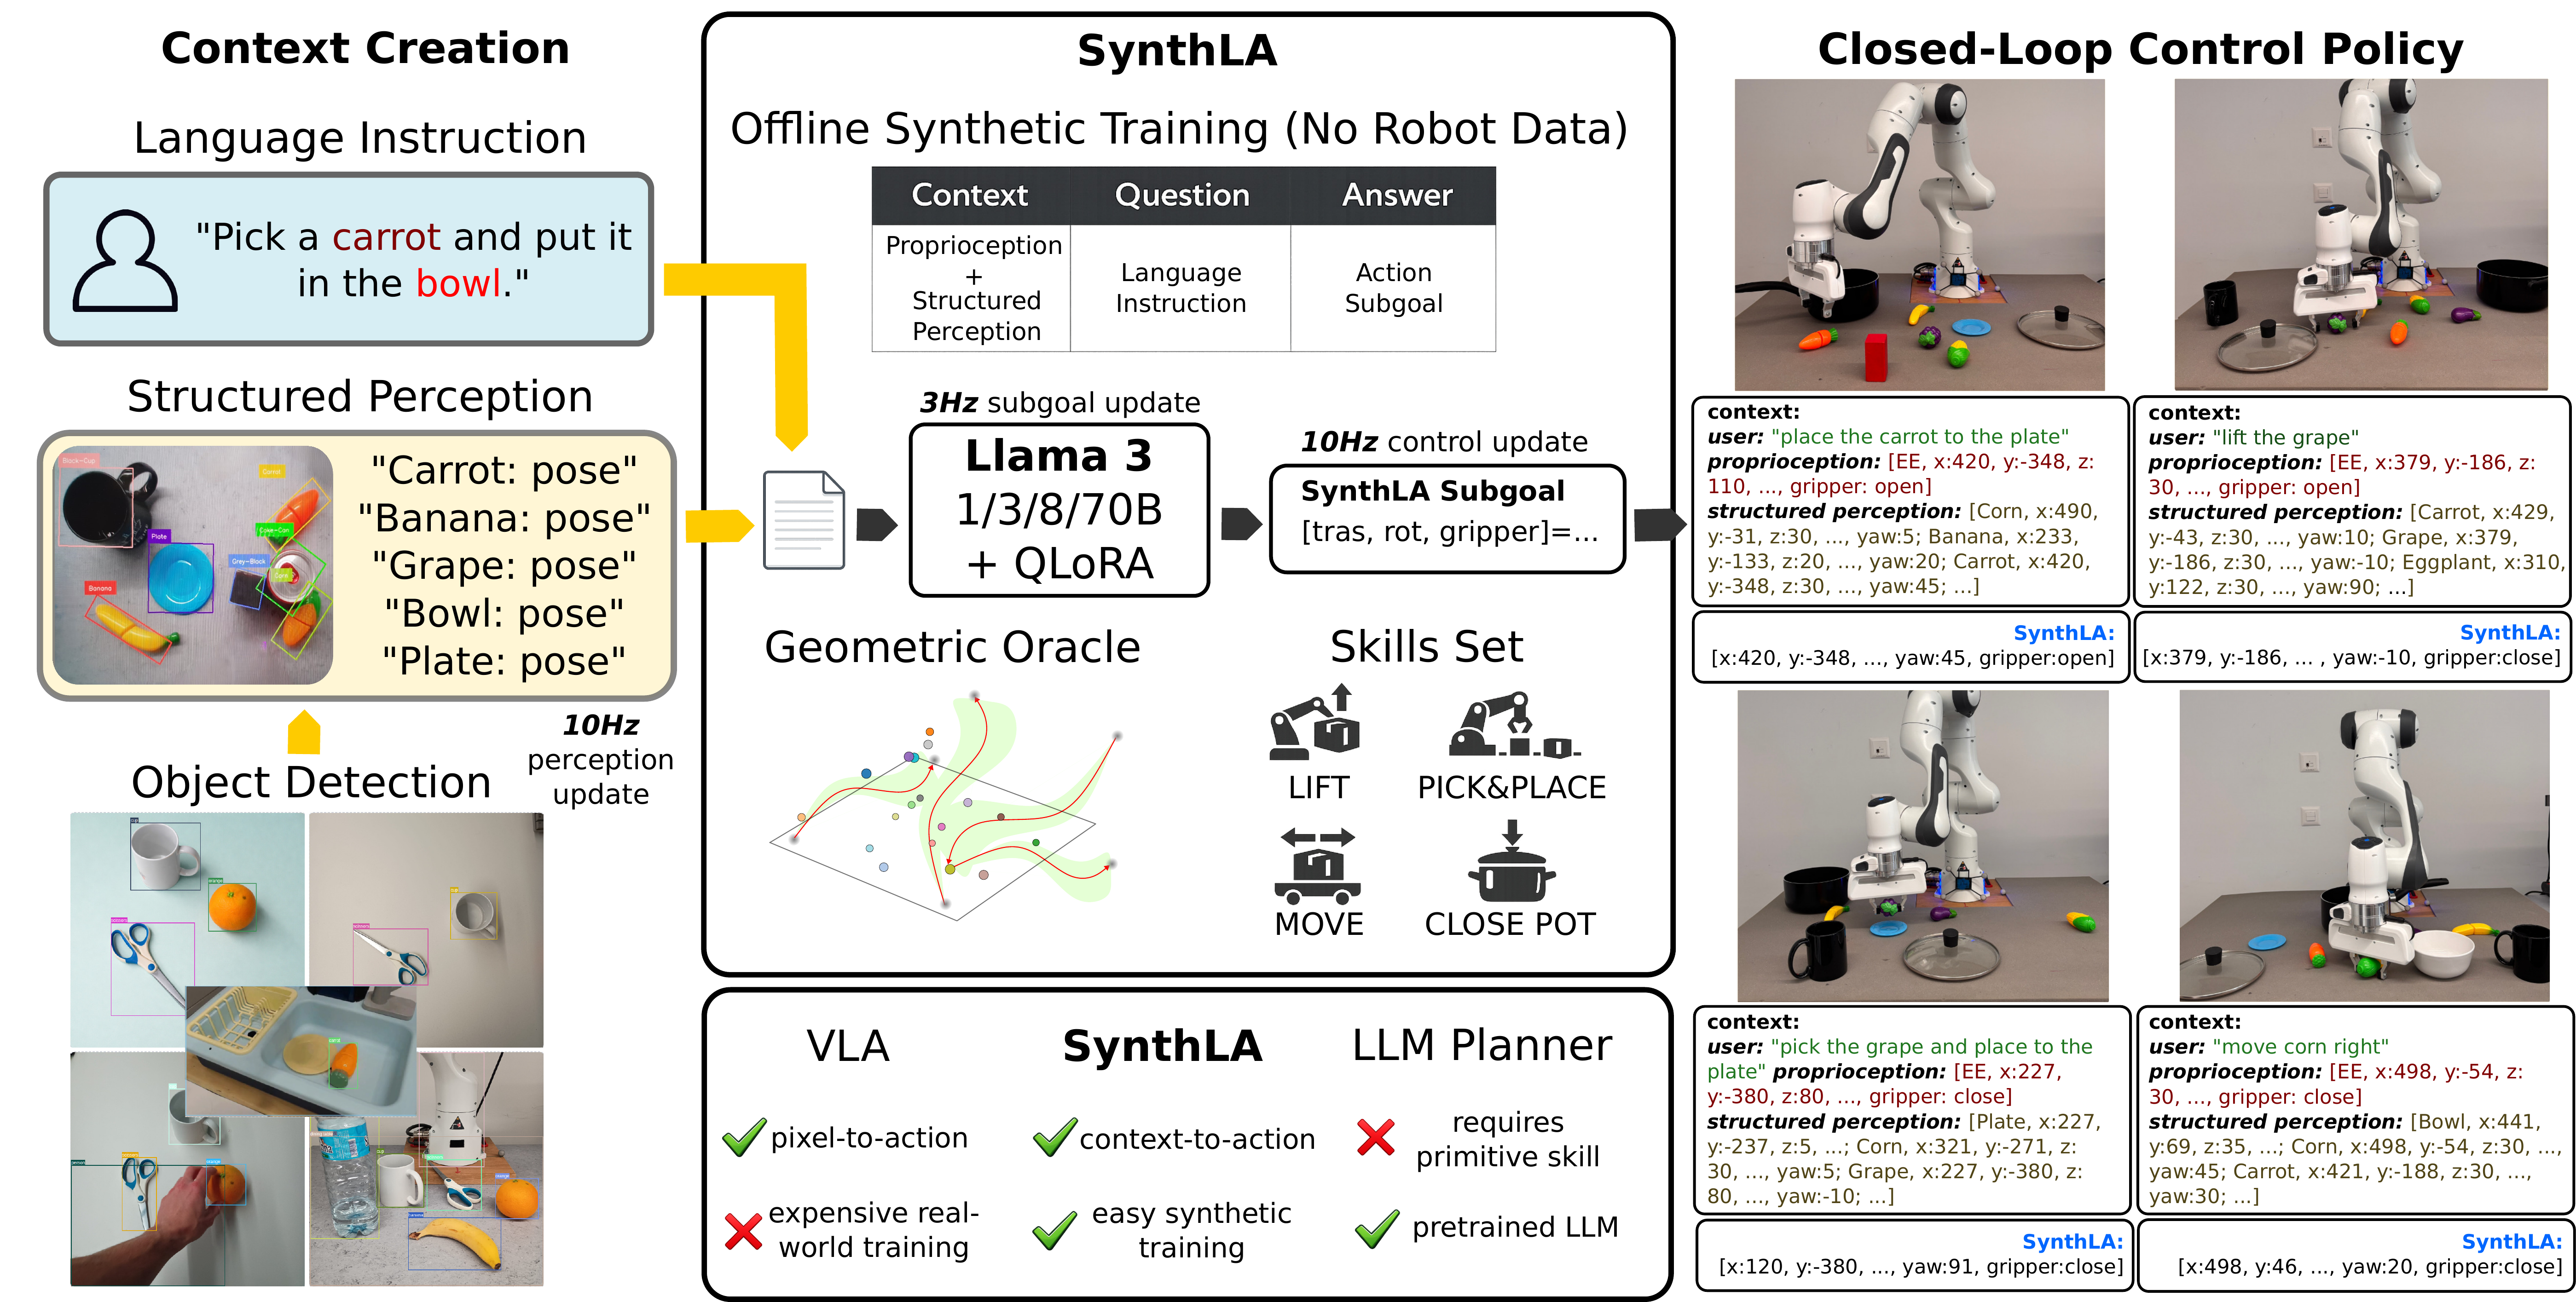
SynthLA
IEEE/RSJ IROS 2026
Synthetic language-action policies for zero-shot real-world manipulation through structured perception.
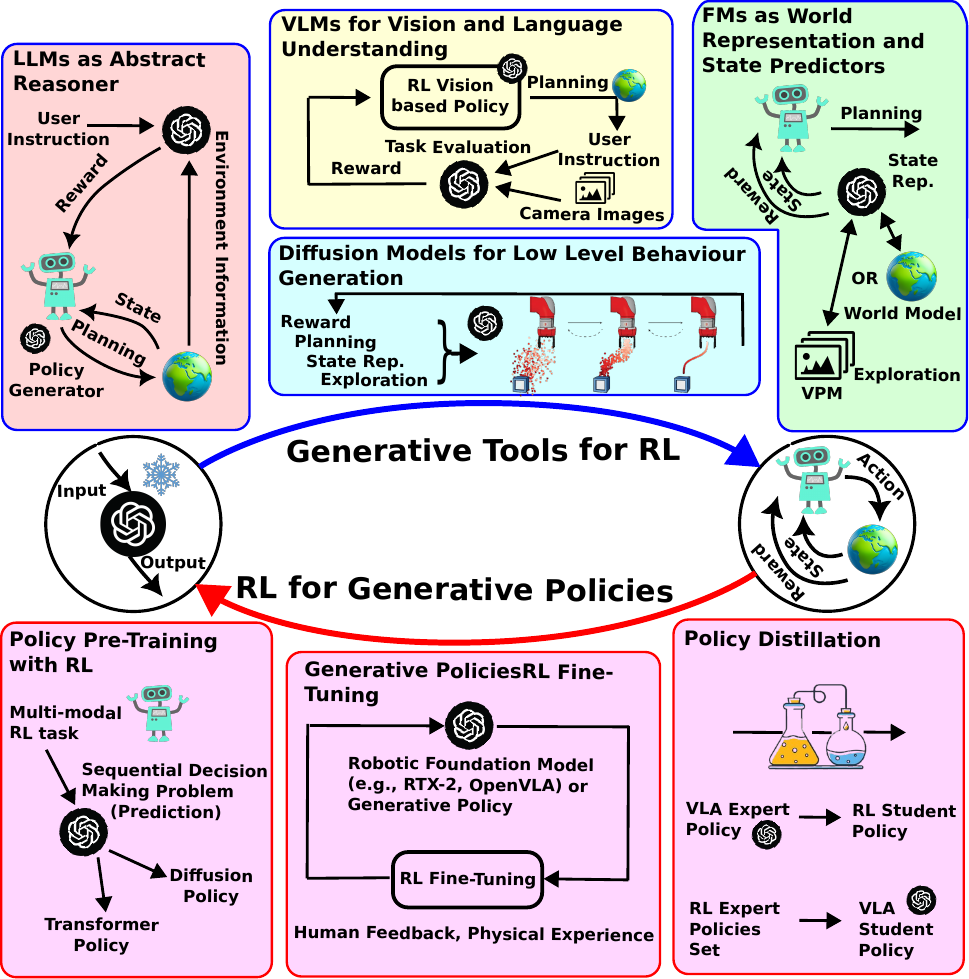
The Duality of Generative AI and Reinforcement Learning in Robotics
Information Fusion, 2025
A review of how generative AI and reinforcement learning complement each other in robotic systems.
Research Interests
Generative Policies
Diffusion models, flow-based models, and generative priors for robot learning.
Vision-Language-Action Models
Foundation models for grounding high-level semantics into robotic control.
Reinforcement Learning
Exploration, jump-starting, robustness, and data-efficient skill acquisition.
Robot Manipulation
Real-world experimentation, sim-to-real learning, and embodied decision-making.
Current Position
I am a Ph.D. researcher at IDSIA USI–SUPSI in Lugano, Switzerland, where I work on Generative AI for Robotic Systems.
I am supervised by Prof. Loris Roveda, with Prof. Alessandro Giusti and Prof. Luca Gambardella as advisors.